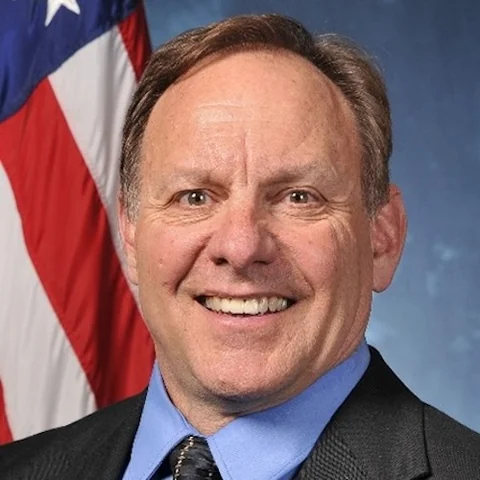
Dr. John Gordon Blitch is a retired United States Army lieutenant colonel, robotics pioneer and cognitive psychologist whose career moved through Pershing II nuclear missile operations, Special Forces, the Defense Advanced Research Projects Agency, disaster-response robotics and research into human interaction with automated systems. Those achievements give him an unusual place in contemporary UAP discussion. Since 2025, Blitch has also spoken publicly about anomalous experiences that he interprets as encounters with Non-Human Intelligence, including childhood episodes, an unexplained period of missing time and an encounter with a mantis-like being.
The two parts of his public life require different evidentiary treatment. His work in robotics, DARPA research, the World Trade Center disaster response and cognitive psychology is documented through technical publications, institutional records and contemporary reporting. His UAP experiences are principally first-person testimony. Blitch has stated that he never had any official discussions about UAP, extraterrestrials or interdimensional beings during his military service. His former clearances and technical career therefore establish professional experience, not privileged official knowledge of a UAP programme.
That distinction is central to understanding why Blitch matters. He is neither simply a former government official making disclosure claims nor only an experiencer recounting extraordinary events. He is a technologist whose established work focused on machines operating beyond normal human reach, and later on the cognitive limits of people controlling those machines, who eventually concluded that some events in his own life could not be explained within the categories he had previously used.
From Massachusetts to West Point
Blitch has said that he was born in Idaho Falls, Idaho, in 1959 and spent part of his childhood in Peabody, Massachusetts. Publicly accessible documentation of his early family life is limited, and the details he has discussed are principally autobiographical. This matters because some of those childhood memories later became part of his UAP testimony, although for decades he says he interpreted them simply as disturbing dreams.
Blitch entered the United States Military Academy and graduated in 1981. His self-authored curriculum vitae, hosted on Academia.edu under his United States Air Force Academy profile, lists a Bachelor of Science in civil engineering with an environmental-engineering emphasis. It also records professional military education at the United States Army Command and General Staff College, including Military Education Level 4 certification, followed by graduate study at the Colorado School of Mines and Colorado State University. His later degrees and much of this educational chronology are independently supported by university and professional records.
According to the same curriculum vitae, Blitch served as a Pershing II missile battery commander from 1985 to 1987, subsequently commanded Operational Detachment Alpha teams in the 10th Special Forces Group and later served as a troop commander in the Combat Applications Group. Contemporary material independently describes him as a retired Special Forces lieutenant colonel and former DARPA programme manager, but the precise sequence of sensitive unit assignments remains principally self-documented. Those details are therefore best attributed to Blitch rather than treated as independently verified personnel history.
Two problems recur throughout his military and technical career. The first is risk: how to obtain information or perform an action in a location where sending a person could result in death or serious injury. The second is control: how much decision-making can safely be delegated to a machine while keeping human beings responsible for the outcome. Those questions eventually became organising principles of his work in robotics.
Oklahoma City and the turn towards rescue robotics
A decisive event came in April 1995, when Blitch was a graduate student on leave from the Army at the Colorado School of Mines. Following the bombing of the Alfred P. Murrah Federal Building in Oklahoma City, he participated in the response. The Association for Computing Machinery later recorded that the experience led him to recognise that robots of suitable size, capability and intelligence were not available for urban search and rescue, and that he redirected his graduate work accordingly.
Blitch translated that problem into research. In 1996 he and Ruth Maurer published work on KNOBSAR, a knowledge-based system intended to improve the management of robotic search assets in collapsed structures. The project did not imagine robots replacing firefighters or structural-rescue specialists. It treated them as remotely deployable tools that could reach denied spaces while intelligent decision-support systems helped incident commanders decide how limited robotic resources should be allocated.
A companion paper, “Artificial intelligence technologies for robot assisted urban search and rescue”, extended this line of thinking into navigation, resource allocation and mobile robotic systems for earthquakes, explosions and military operations. Blitch’s interest was operational rather than purely theoretical. The central question was whether artificial intelligence and portable machines could extend human reach into environments where ordinary entry was impossible or excessively dangerous.
Blitch was not the sole originator of rescue robotics. Researchers including Robin Murphy were developing crucial work in field robotics, artificial intelligence and human-machine interaction. Blitch’s particular contribution lay in connecting those technologies to operational requirements. His background encouraged questions that laboratory demonstrations could evade: Could the machine survive rubble? Could rescuers transport it? Could it communicate through a damaged structure? Could it recover when overturned? Would the information it returned actually help an incident commander?
Special Operations requirements and DARPA
After graduate study, Blitch’s curriculum vitae records service at United States Special Operations Command as an operations research analyst and project manager concerned with portable robotic systems. He states that this work included requirements for aerial, aquatic and ground platforms intended to enter denied environments, together with field experimentation involving operational personnel. Since the detailed programme history is primarily found in his own professional record, those particulars remain appropriately attributed to him.
In 1998 Blitch moved to DARPA, where his position as a programme manager is independently established. He became closely associated with the Tactical Mobile Robotics programme. A 1999 paper co-authored with Eric Krotkov described the programme as an effort to create teams of small, relatively low-cost, semi-autonomous robots for urban reconnaissance, supported by advances in machine perception, autonomous operation and difficult-terrain locomotion. Both authors were then affiliated with DARPA’s Tactical Technology Office.
Blitch succeeded Krotkov in managing the programme and emphasised practical urban operations. Contemporary accounts described systems ranging from rugged tracked machines to throwable reconnaissance robots and larger platforms capable of deploying smaller ones.
A particularly useful contemporary source predating the World Trade Center attacks is Sandra I. Erwin’s May 2001 article in National Defense. Erwin identified “Army Lt. Col. John G. Blitch” as the programme manager for tactical mobile robots and recorded his concern with operator proficiency, obstacle negotiation, human intervention and the need to assign machines tasks that would otherwise expose people to danger. The article independently confirms that these were already central issues in Blitch’s work before rescue robotics became widely associated with the events of September 2001.
The engineering objective was not unrestricted machine autonomy. It was resilient mobility, remote observation and increasing machine assistance in places where obstacles were unpredictable and communication could disappear without warning. Robots had to negotiate debris, recover from failures and return useful information to human operators.
The same technology carried an unavoidable dual-use tension. A machine capable of entering a collapsed building could also reconnoitre a defended structure. Technology developed to keep rescuers away from unstable rubble could keep soldiers away from hostile fire. Blitch’s later writing repeatedly returned to this boundary between life-saving automation and the possibility that physical distance could also distance decision-makers from responsibility.
Ground Zero and a historic deployment
Blitch completed his Army retirement processing at the Pentagon on 10 September 2001. After the attacks the following morning, he mobilised roboticists, manufacturers and available machines for New York. ACM’s account states that he contacted teams within minutes of the second aircraft striking the World Trade Center and organised what became the first known robot-assisted urban search-and-rescue operation.
The exact arrival chronology deserves careful wording. Blitch has said that he reached Ground Zero on the evening of 11 September. Operational accounts place the organised CRASAR deployment at the site by the morning of 12 September. The documented conclusion is therefore that Blitch moved rapidly to New York and that CRASAR personnel and robots were operating at the disaster site during the earliest phase of the response.
The World Trade Center response became a foundational event in rescue robotics. Small teleoperated machines entered voids and damaged structures that were unsafe or inaccessible to people and search dogs. CRASAR coordinated teams from organisations including the University of South Florida, Foster-Miller, iRobot and the Space and Naval Warfare Systems Center. A 2002 AI Magazine article by Robin Murphy, John Blitch and Jeff Casper records four robotic teams responding through CRASAR and identifies Blitch as the organisation’s director.
The machines did not turn Ground Zero into an autonomous-robot operation. Dust, unstable debris, communications problems, battery limitations, awkward locomotion and operator workload imposed severe constraints. Their importance lay in extending human perception into dangerous spaces and proving that mobile robots could become legitimate emergency-response tools rather than remaining laboratory demonstrations.
Blitch received the 2001 ACM Eugene L. Lawler Award for Humanitarian Contributions within Computer Science and Informatics. ACM’s citation specifically recognised his leadership in the prior development and rapid deployment of the urban search-and-rescue robots used at the World Trade Center. It also credits him with organising the response and with building relationships between roboticists and the rescue community before the attacks occurred.
Afghanistan, industry and ARACAR
After leaving active military service, Blitch joined Science Applications International Corporation in a senior robotics role. His curriculum vitae states that he later returned temporarily to government service and supported a deployment of tactical mobile robots during Operation Enduring Freedom, including work involving remote underground locations. Because the detailed operational circumstances are chiefly described in his own professional record, the episode cannot be reconstructed publicly with the same confidence as the World Trade Center response.
Blitch later founded Blitz Solutions Incorporated and the Alliance for Robot-Assisted Crisis Assessment and Response, or ARACAR. A 2017 BrainFacts profile independently records his leadership of Blitz Solutions and ARACAR and notes that ARACAR participated in Hurricane Katrina response and other crisis-assessment and rescue activities.
The organisations addressed a persistent weakness in humanitarian robotics. A sophisticated robot is not an emergency-response capability by itself. Effective deployment also requires trained operators, maintenance, transport, communications, command relationships and enough routine work to preserve readiness between disasters. Blitch attempted to sustain those capabilities through consulting and commercial work alongside humanitarian response.
A serious leg injury eventually interrupted that phase of his career. Blitch’s curriculum vitae states that medical complications forced him to close the organisations and return to graduate school. The result was a significant intellectual shift. He moved from asking what machines could do in dangerous environments to asking what automation did to the people operating them.
The cognitive psychologist
At Colorado State University, Blitch earned a Master of Science in psychology in 2012. His thesis, Implications for Automation Assistance in Unmanned Aerial System Operator Training, examined whether automated assistance during training could undermine later unaided performance. The university’s Mountain Scholar repository confirms the degree and study, which used an unmanned aerial-system simulator and found poorer subsequent landing performance among trainees who had received automation assistance on part of the task.
He completed a Doctor of Philosophy in psychology at Colorado State in 2014. His dissertation, Engagement and not workload is implicated in automation-induced learning deficiencies for unmanned aerial system trainees, investigated why automated assistance could produce training deficits. Three experiments failed to support a simple explanation based on reduced workload. Instead, Blitch concluded that distraction and disengagement were more strongly implicated in weakened mental models produced by automation-assisted training.
The finding extended a problem already present in his robotics career. Automation can reduce immediate effort and protect a human operator while simultaneously weakening the attention or skill needed when the machine reaches its limits. A related peer-reviewed paper with Robert Gutzwiller and Benjamin Clegg examined automation in the context of part-task training and argued against treating all methods of simplifying complex tasks as cognitively equivalent.
By 2017, BrainFacts described Blitch as a senior research scientist recently hired by the Air Force Research Laboratory’s 711th Human Performance Wing in cognitive psychology and neuroscience. The same profile corroborates his Colorado School of Mines graduate degree, his DARPA programme-management role, his founding involvement with CRASAR and his later doctorate in cognitive psychology.
A reasonable biographical reading is that his professional life had by then revolved around a common boundary: the relationship between human agency and systems operating at a distance. Early in his career, machines extended human action into places the body could not safely reach. Later, he examined how those same systems could alter attention, learning and responsibility. That background may help explain some of the conceptual language he later brought to UAP experiences, but it does not independently validate his interpretation of those experiences.
Writing about rescue robots and responsibility
Blitch eventually brought much of this history together in Killer Rescue Robot kNOT: The Case for Robot-Assisted Rescue in the Modern World. Public ISBN metadata records the book as published in 2025 by “Independently published”, with ISBN 9798269356457.
The book combines memoir, robotics history and an argument about responsibility in increasingly automated environments. Its underlying problem is consistent with the rest of Blitch’s career: technology can keep human beings out of danger, but the same distancing effect can complicate accountability. The book is an autobiographical interpretation rather than an independent history of rescue robotics, but it offers a useful account of how Blitch understands the relationship between his military, engineering and humanitarian work.
A second public identity emerges
For most of his professional career, Blitch’s anomalous experiences remained separate from his public technical work. That changed in January 2025 when he appeared with Ross Coulthart on NewsNation’s Reality Check. The interview concerned both Blitch’s own anomalous experiences and his assessment of UAP claimant Jake Barber.
Blitch explicitly separated his personal experiences from his government career. He stated that he had never had any official discussions about UAP, extraterrestrials or interdimensional beings during his military service. He further said that the sensitive programmes in which he worked had not provided him with formal access to the phenomenon as he now understands it.
That statement should be read narrowly as Blitch describing his own access. It neither proves nor disproves the existence of programmes beyond that access.
What changed was his interpretation of earlier personal experiences. Blitch has said that frightening childhood episodes were originally categorised as dreams. He recalled figures with unusually large, dark eyes outside his bedroom window and experiences involving intense fear and apparent paralysis. He says he did not treat these events as evidence of NHI for most of his life. Only later, after additional experiences, did he begin to interpret them as part of a larger pattern.
That chronology is essential. The memory of the childhood experience is one evidentiary layer. The later conclusion that the experience involved NHI is another.
The 1995 missing-time account
Blitch’s most detailed anomalous account concerns a mountain-bike ride in Colorado in 1995, shortly after his participation in the Oklahoma City response. He says that during a familiar ride near Daniels Park and the MacArthur Ranch area, he experienced an unusual urge to cross a fence into an area he normally regarded as restricted.
According to Blitch, he began walking his bicycle along a dirt road when he developed a sudden nosebleed. He lay down expecting to recover after a short period, but his next conscious memory was of awakening intensely cold. He then moved towards a light, encountered what he initially interpreted as a vehicle and eventually returned towards a populated road.
Blitch recalls reaching a convenience store exhausted and extremely thirsty. He says a police officer told him that his wife had reported him missing, and that his family subsequently informed him that a ride expected to take around an hour had lasted approximately five hours.
No such contemporaneous police, shop or other record was located among the publicly accessible sources reviewed for this article. The reported police interaction and duration therefore remain elements of Blitch’s testimony rather than independently established chronology.
Blitch now believes that he was taken during the missing interval, but he has also distinguished this conclusion from memories he retained consciously. That distinction is methodologically important because he later underwent hypnotic regression and has not treated material reconstructed during hypnosis as equivalent to his ordinary memory.
Contemporary memory research supports that caution. A 2025 review in Frontiers in Psychology concluded that hypnotic regression and guided imagery should be used cautiously because they may contribute to memory distortion and false recollection. This literature does not determine what happened to Blitch. It does mean that hypnosis-derived imagery cannot independently establish the history of the missing interval.
Bruises, memory and interpretation
Blitch has also described waking after another frightening experience with dark bruises on his upper arm. He interpreted their arrangement as resembling the marks left by a gripping hand and says he filmed them. He later regarded the bruising as one of the observations that caused him to reconsider his previous assumption that the experiences were dreams.
The bruises are relevant because they represent a claimed physical observation rather than an experience occurring only within memory. Their evidentiary value is nevertheless limited by the absence, in publicly available material, of contemporaneous medical examination, independent chain-of-custody documentation or another method capable of establishing their cause.
Blitch has similarly described an intense physiological reaction on seeing the face depicted on the cover of Whitley Strieber’s Communion, which he associated with figures remembered from childhood. The reaction is meaningful as part of his personal history because it illustrates the emotional force of the memory. It cannot independently identify what produced the original experience.
The mantis-like encounter
The most unusual element of Blitch’s testimony concerns what he describes as a roughly seven-foot mantis-like being. He places the experience in approximately the same period as the 1995 mountain-bike episode. In his account, he was in an upstairs bedroom when the figure appeared to pass through a screened doorway and stand over him while he was unable to move.
Blitch says the being communicated without ordinary speech and conveyed a distinction between the physical body and consciousness. He recalls imagery in which tissue appeared to be torn from his cheek, apparently to communicate that damage to the body did not amount to destruction of consciousness. Significantly, he has acknowledged that no corresponding physical wound existed afterwards.
That acknowledgement preserves an important boundary between the perceived encounter and imagery experienced within it. Blitch nevertheless regards the mantis-like figure as a sentient intelligence. By contrast, he has proposed that some smaller grey-like beings described in encounter reports might function as biological robots. No publicly available biological specimen or independently verified observation establishes that classification.
His professional background supplies an obvious conceptual analogy. Someone who spent decades distinguishing a robotic platform from its controller, and autonomous behaviour from remote control, has a vocabulary readily adaptable to the possibility that an apparently biological entity could be an engineered intermediary. That may help explain the structure of Blitch’s hypothesis. It is not evidence for the hypothesis itself.
Jake Barber and the credibility question
Blitch’s public emergence in UAP discussion was closely connected to Jake Barber, a former military figure who has alleged participation in retrieval operations involving anomalous vehicles. Blitch told Coulthart that he had met Barber and associates before Barber’s public emergence and had attempted to assess their credibility. He cited behaviour, documentation he says he inspected, consistency and military context as reasons he regarded them as credible.
This endorsement has clear limits. Blitch’s military and technical background may make his assessment noteworthy, but the documents he says he examined have not been released in a form that permits independent public evaluation. His conclusion about Barber therefore remains an informed personal assessment rather than external verification of Barber’s broader retrieval claims.
Blitch has also expressed confidence that recovered anomalous vehicles and non-human bodies exist and has discussed the possibility that high-powered electromagnetic or microwave systems could interfere with anomalous craft. Those assertions extend beyond his own documented firsthand experience. No publicly released technical dataset from Blitch demonstrates that anomalous vehicles have been brought down using such methods.
Abduction, secrecy and the “amnesty” idea
Blitch’s most distinctive contribution to current UAP advocacy is his argument that reported abduction experiences may help explain prolonged secrecy. He proposes that officials confronted with an intelligence substantially more capable than humanity might have concealed the phenomenon partly because they could not protect citizens from involuntary encounters.
In this model, secrecy is not explained solely through recovered technology, military advantage or bureaucratic classification. It is also associated with institutional helplessness. If an intelligence could enter private spaces, manipulate perception and remove people without effective resistance, disclosure would raise an uncomfortable question about the limits of governmental protection.
Blitch couples that interpretation with an argument for forgiveness. Rather than approaching disclosure entirely as a search for officials to punish, he advocates an amnesty or reconciliation framework involving alleged abductors, human institutions involved in concealment and experiencers carrying trauma, guilt or feelings of helplessness.
He is developing this position in The Abduction Amnesty Knot. As of October 2026, Blitch’s own Fear Fighter website continued to list the book as “coming soon”.
The argument is distinctive because it reverses the usual direction of disclosure politics. Instead of beginning with the question of who should be prosecuted for secrecy, it begins with what institutions might have done if they genuinely lacked the ability to prevent the underlying events. The framework depends on unresolved empirical propositions, particularly that NHI abductions occur and that government actors possess confirming knowledge. Its ethical argument can therefore be considered separately from the evidentiary status of those premises.
A growing UAP public role
Blitch’s involvement in organised UAP discussion expanded in 2026. In June he presented at the Society for Scientific Exploration’s 44th Annual Conference, Evidence & Encounters: Two Paths to Exploring the Unexplained, held in Westminster, Colorado.
The detailed conference programme places “Empirical Elephants in the UAP Room” within the Thursday UAP session. Robin Carhart-Harris delivered the opening keynote. Blitch should therefore be described as a conference presenter rather than a keynote speaker.
On 1 October 2026, Blitch also participated in the Beyond Institute’s inaugural Stockholm event, Is Humanity Alone on Earth?. The official programme listed him among the participants, while co-organiser Beatriz Villarroel’s post-event account states that the first science panel featured Blitch alongside Marik von Rennenkampff, Stephen Bruehl and Villarroel. Villarroel reported discussion of astronomical transients, government-released data, scientific approaches to reported abduction experiences and claimed relationships between UAP activity and nuclear sites. Blitch also appeared in a subsequent session involving military witnesses.
These appearances mark a significant change in public role. Blitch is no longer speaking only as a roboticist who reports anomalous experiences. He has become an advocate for treating encounter testimony, including reports of abduction, as a serious part of the UAP research problem.
That shift should not erase the evidentiary distinction between his technical record and his anomalous claims. His biography is noteworthy precisely because the same individual presents both extensively documented professional achievements and extraordinary experiences that presently lack comparable external corroboration.
Credentials and the limits of credentials
Blitch’s professional history matters when evaluating his testimony, but not because professional accomplishment makes an anomalous interpretation correct. His record establishes experience with military operations, robotics, risk, automation, scientific research and cognitive psychology. Those skills may inform how he describes experiences and may make him unusually conscious of questions involving perception and memory.
They cannot independently determine the cause of an event that lacks sensor data, medical documentation or contemporaneous independent records.
The opposite error is equally unhelpful. Reporting an anomalous experience does not retroactively invalidate a documented career. Blitch’s contributions to rescue robotics, DARPA research and human-machine interaction exist independently of whether his interpretation of his encounter experiences is eventually supported, modified or rejected.
His own testimony contains several useful epistemic distinctions. He separates official access from personal belief, consciously retained recollection from hypnotically reconstructed material, and a vividly perceived bodily injury from the acknowledgement that no physical wound existed afterwards. These distinctions do not verify NHI involvement. They make his account more analytically useful because he does not present every component of the experience as evidentially equivalent.
Legacy
Blitch’s established legacy lies in rescue robotics and human-machine systems. His experience at Oklahoma City redirected his graduate work towards machines capable of entering collapsed structures. His academic research translated that need into robot-assisted search concepts. At DARPA he helped develop tactical mobile robotics, and after the World Trade Center attacks he organised a response that became the first known operational use of robots for urban search and rescue. His later cognitive research examined the human-machine relationship from the opposite direction, asking how automation affects learning, engagement and responsibility.
His place in UAP history remains unresolved. Blitch has not claimed that his DARPA role gave him formal access to a UAP programme. His significance instead derives from the combination of an independently documented high-responsibility career and detailed first-person encounter testimony. That combination makes his account worthy of preservation, but it cannot substitute for corroboration.
Several forms of evidence could materially alter the picture: a contemporaneous police report connected to the 1995 incident, independently preserved medical or photographic records, corroborating witnesses, verifiable documentation associated with individuals whose claims he endorses, or reproducible physical evidence connected to the reported encounters. Without such material, the anomalous portion of his biography remains serious testimony rather than established event history.
Blitch is therefore an instructive figure for UAP research because his life illustrates both the value and the limits of expertise. A person can be demonstrably accomplished in robotics, military operations and cognitive science while reporting experiences that remain unresolved by those disciplines. The responsible historical approach is neither to allow his credentials to prove the encounters nor to allow the encounters to erase his credentials. It is to preserve both records accurately and allow future evidence to determine whether they eventually converge.
References
Association for Computing Machinery. (n.d.). John Blitch: ACM Eugene L. Lawler Award for Humanitarian Contributions within Computer Science and Informatics, 2001. ACM Awards.
Behar, M. (2002, May 1). The new mobile infantry. Wired.
Blitch, J. G. (1996). Artificial intelligence technologies for robot assisted urban search and rescue. Expert Systems with Applications, 11(2), 109–124. https://doi.org/10.1016/0957-4174(96)00038-3
Blitch, J. G. (2012). Implications for automation assistance in unmanned aerial system operator training [Master’s thesis, Colorado State University]. Mountain Scholar. https://doi.org/10.25675/3.020135
Blitch, J. G. (2014). Engagement and not workload is implicated in automation-induced learning deficiencies for unmanned aerial system trainees [Doctoral dissertation, Colorado State University]. Mountain Scholar. https://doi.org/10.25675/3.019721
Blitch, J. G. (2025). Killer Rescue Robot kNOT: The case for robot-assisted rescue in the modern world. Independently published. ISBN 9798269356457.
Blitch, J. G. (n.d.). Curriculum vitae [Self-authored CV hosted on Academia.edu under United States Air Force Academy profile].
Blitch, J. G., & Maurer, R. (1996). KNOBSAR: A knowledge-based system prototype for robot-assisted urban search and rescue. Simulation, 66(6), 375–391. https://doi.org/10.1177/003754979606600605
BrainFacts. (2017, March 24). People Behind the Science: John Blitch. Society for Neuroscience.
Erwin, S. I. (2001, May 1). Battlefield robots: Not just “entertainment”. National Defense.
Gutzwiller, R. S., Clegg, B. A., & Blitch, J. G. (2013). Part-task training in the context of automation: Current and future directions. The American Journal of Psychology, 126(4), 417–432. https://doi.org/10.5406/amerjpsyc.126.4.0417
Krotkov, E., & Blitch, J. G. (1999). The Defense Advanced Research Projects Agency Tactical Mobile Robotics Program. The International Journal of Robotics Research, 18(7), 769–776. https://doi.org/10.1177/02783649922066457
Leo, D. G., Bruno, D., & Proietti, R. (2025). Remembering what did not happen: The role of hypnosis in memory recall and false memories formation. Frontiers in Psychology, 16, 1433762. https://doi.org/10.3389/fpsyg.2025.1433762
Murphy, R. R. (2004). Trial by fire [rescue robots]. IEEE Robotics & Automation Magazine, 11(3), 50–61. https://doi.org/10.1109/MRA.2004.1337826
Murphy, R. R., Blitch, J., & Casper, J. (2002). AAAI/RoboCup-2001 urban search and rescue events. AI Magazine, 23(1), 37–42. https://doi.org/10.1609/aimag.v23i1.1606
NewsNation. (2025, January 25). Former nuclear officer, Green Beret says he believes UAP whistleblower | Reality Check [Video]. YouTube.
Society for Scientific Exploration. (2026). SSE’s 44th Annual Conference: Evidence & Encounters, Two Paths to Exploring the Unexplained. Westminster, Colorado, 17–21 June 2026.
Society for Scientific Exploration. (2026, July). Explorer: 44th Annual SSE Conference programme and report. Society for Scientific Exploration.
Villarroel, B. (2026, October 5). Beyond Institute’s inaugural panel (2026) in images. Medium.
Beyond Institute. (2026). Beyond Sessions #1: Is Humanity Alone on Earth? Stockholm, 1 October 2026.
Blitch, J. G. (2026). The Abduction Amnesty Knot. Fear Fighter. Forthcoming project listed as “coming soon”, accessed October 2026.
SEO keywords
John Blitch biography, John Gordon Blitch, Dr John Blitch, John Blitch DARPA, John Blitch UAP, John Blitch NHI, John Blitch mantis encounter, John Blitch missing time, John Blitch abduction, rescue robotics, Tactical Mobile Robotics Program, DARPA robotics, World Trade Center rescue robots, Ground Zero robotics, CRASAR, ARACAR, cognitive psychology, automation-assisted training, human-machine teaming, Jake Barber, UAP experiencer, mantid entity, biological robot hypothesis, abduction amnesty, UAP disclosure, Non-Human Intelligence, Killer Rescue Robot kNOT.